These docs are public and open source.Edit on GitHub
THE DRIVETRAIN
A traditional geometry with four-wheel drive, independent suspension, and 80 mm all-terrain tyres.
THE BRUSHED MOTOR + ESC
A purpose-spec brushed motor with integrated encoder. The motor converts electrical energy into mechanical energy to provide power.
The motor is driven by an ESC (electronic speed controller). It reads the control signal and adjusts the power delivered to the motor accordingly, which sets both the speed and the direction the motor turns. This is what gives precise control over the motor's speed and torque. The signal comes from the OSCORE board.
//Motor specs
| Parameter | Specification |
|---|---|
| Type | Brushed DC with integrated encoder |
| No-load speed | ~11,000 RPM |
| Drive | All four wheels, fixed reduction |
| Closed loop | MCU velocity controller |
//The ESC switch
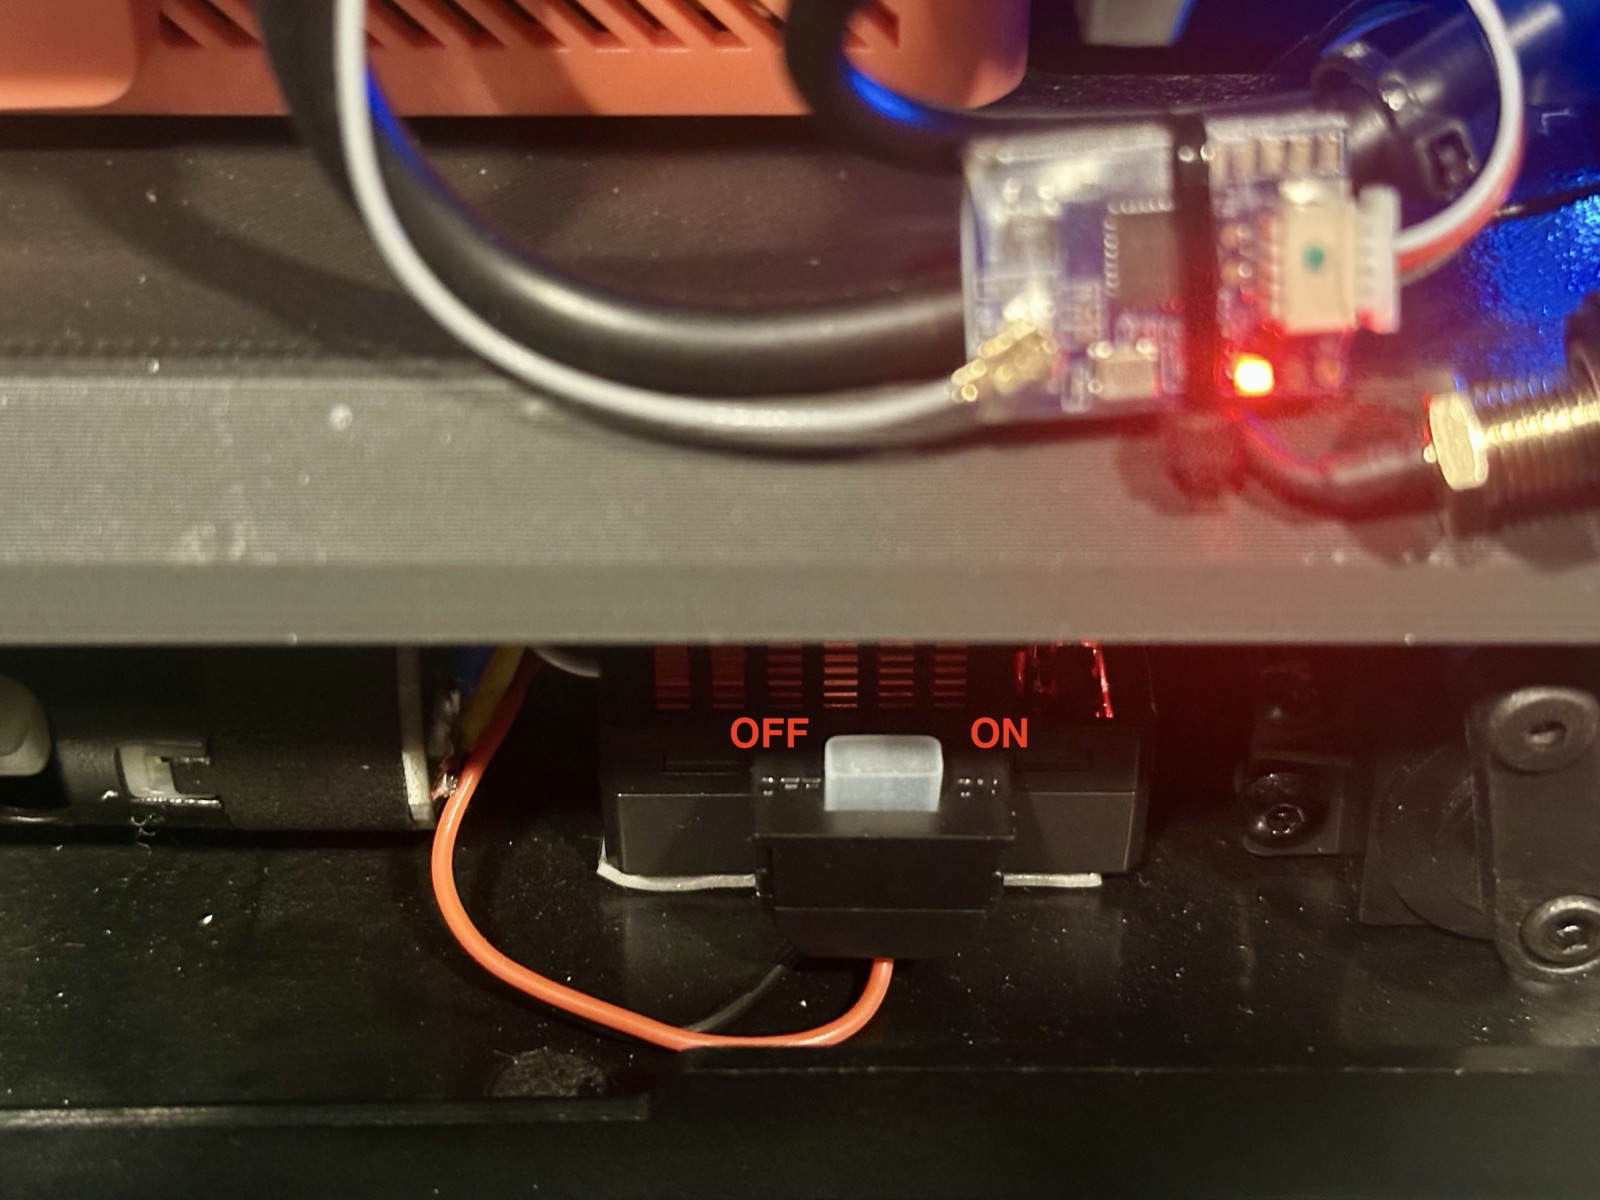
- The ESC has its own switch, located inside the chassis. It is on by default. If the ESC is switched off, the car will not move, even if you use the transmitter.
- To switch it back on, first make sure nothing is sending drive commands to the car, then flip the switch to ON. You will hear a succession of beeps, and the car will operate as normal.
THE STEERING SERVO
The steering servo turns the front wheels. It is much stronger than a car this size needs, so it will not strip its gears if the car hits a wall. It is also waterproof.
//Servo specs
| Parameter | Specification |
|---|---|
| Stall torque | 20 kg·cm |
| Waterproof | Yes |
| Geometry | Ackermann linkage |